
 View on Asset Store (opens in new tab)
Package details
- Latest version
- 2.0
- Last updated
- First released
- Unity version
- 6000.2.8 or later
- Package size
- 95 KB
- Files
- 67
- Favorites
- 2
- Views in the past week
- 15
Price tracking
- Last checked
- Tracked since
- Lowest recorded
- $29.99 on
Keywords
Swarm AI Toolkit - Avoidance & Steering
Swarm AI – Avoidance & Steering adds predictive local collision avoidance and steering behaviors for smooth, natural crowd movement.
Affiliate link · Purchases support this site
Price history
Last 6 months
USDAsset preview
1 / 6
Swarm AI Toolkit - Avoidance & Steering screenshot 1
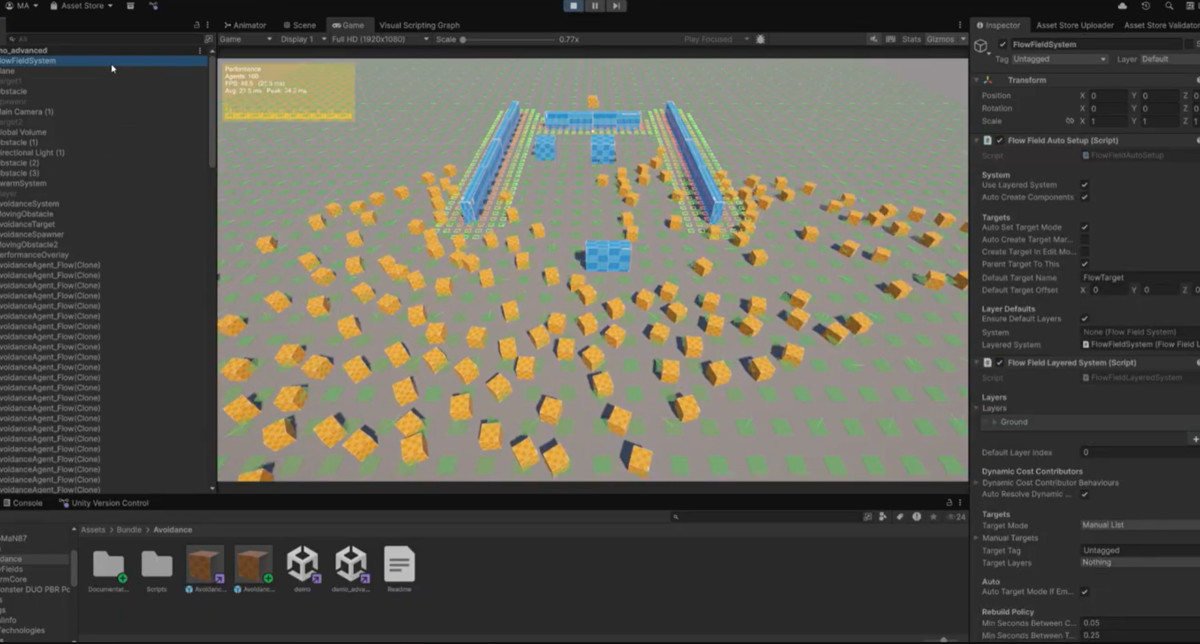
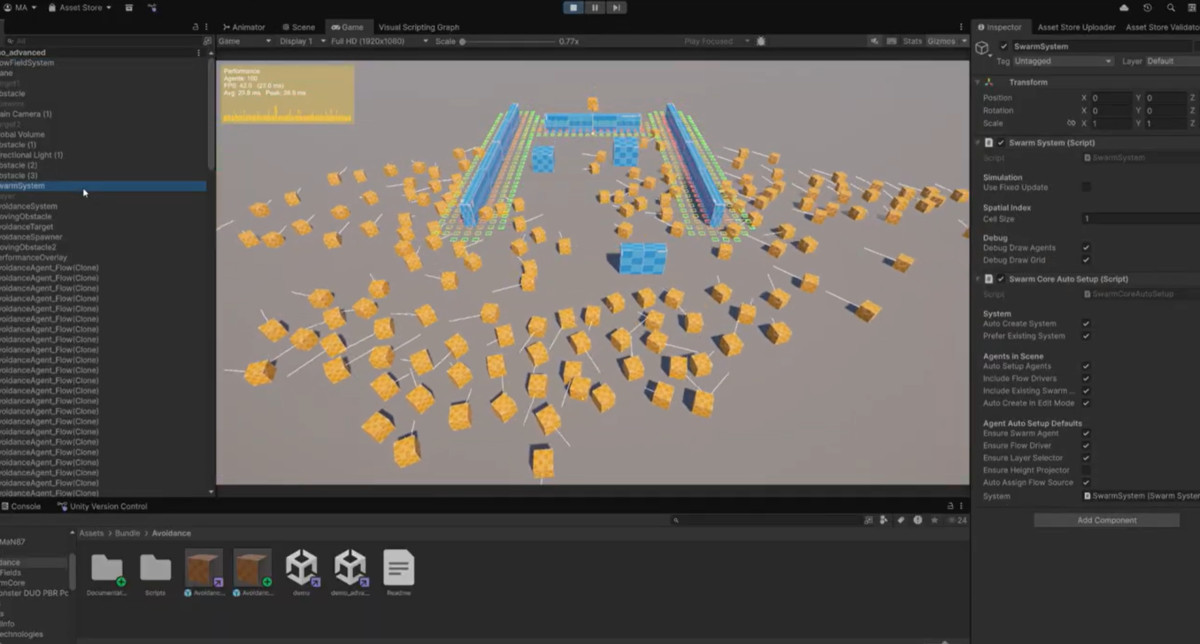
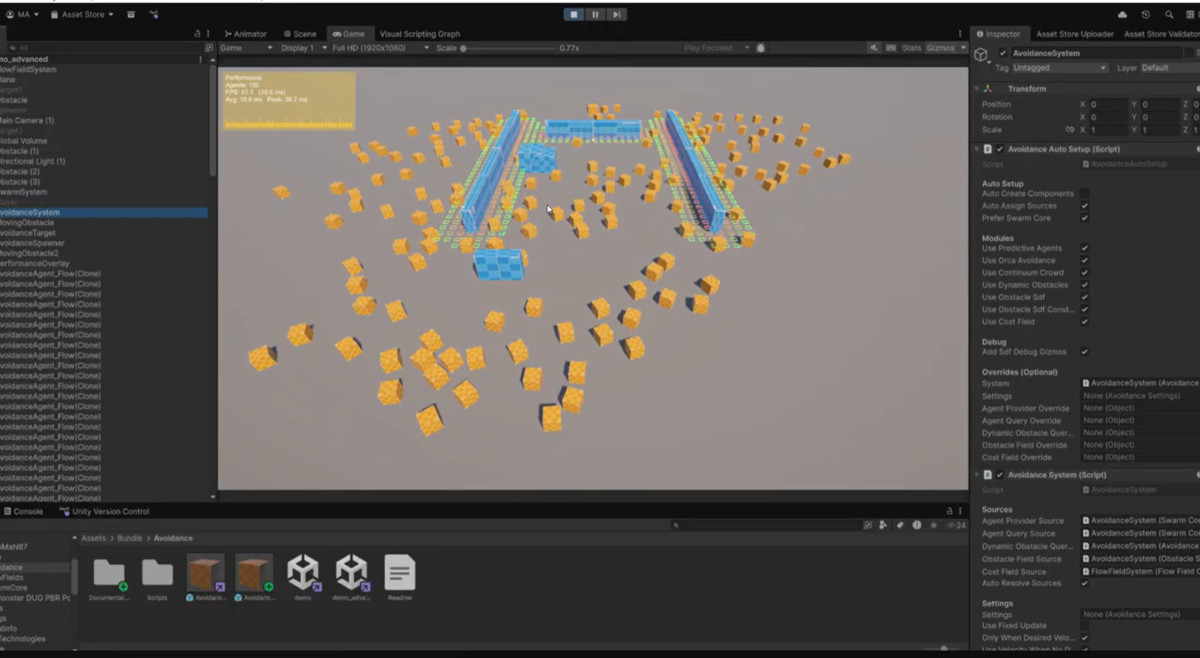
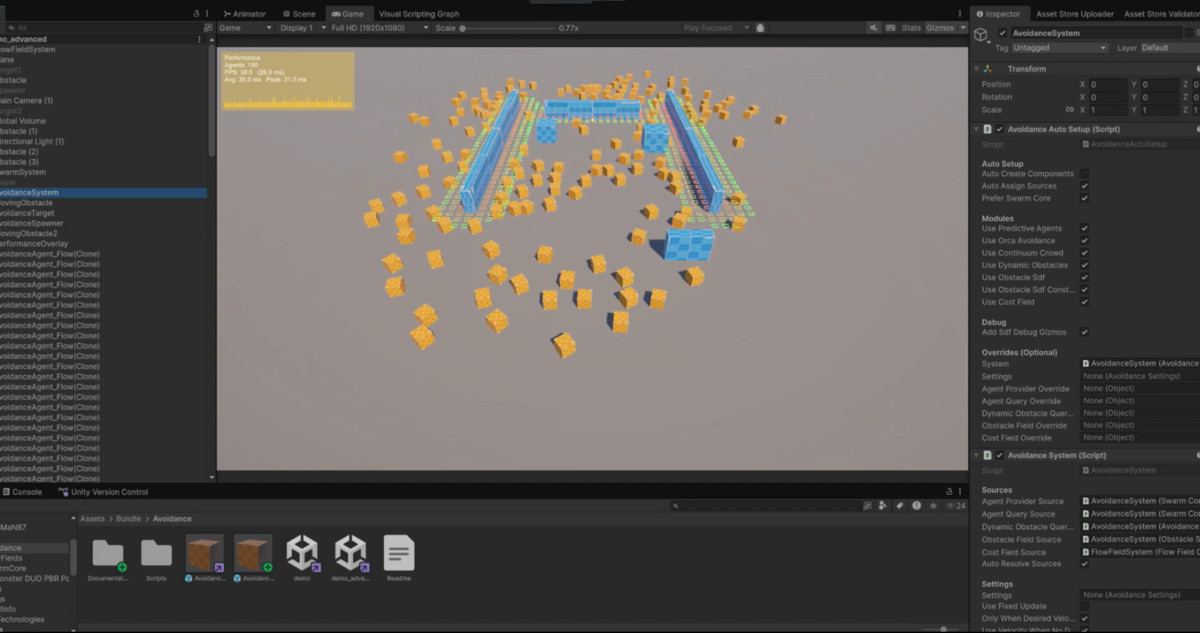
About this asset
Swarm AI - Avoidance & Steering is a performance-focused local movement layer for crowd, swarm, and formation simulations in Unity. It handles the local side of mass movement: keeping agents responsive, avoiding collisions, reacting to density, and producing motion that feels organic instead of robotic.
This module can be used standalone, or combined with Swarm Core and Flow Fields to build a complete movement stack: global direction, local collision resolution, terrain-aware movement, and natural steering.
What It’s For
- City crowds, top-down games, RTS units, simulations, factories, and creature swarms
- Dense agent scenes where per-agent pathfinding becomes too heavy
- Ground, terrain-following, and flying agents
- Movement systems that need smooth local decisions under load
Key Features
Collision Avoidance
- Predictive local collision avoidance for agent-agent interactions
- ORCA 2D for reciprocal planar avoidance
- ORCA 3D-style avoidance for flying agents
- Continuum crowd avoidance for smooth density-based motion
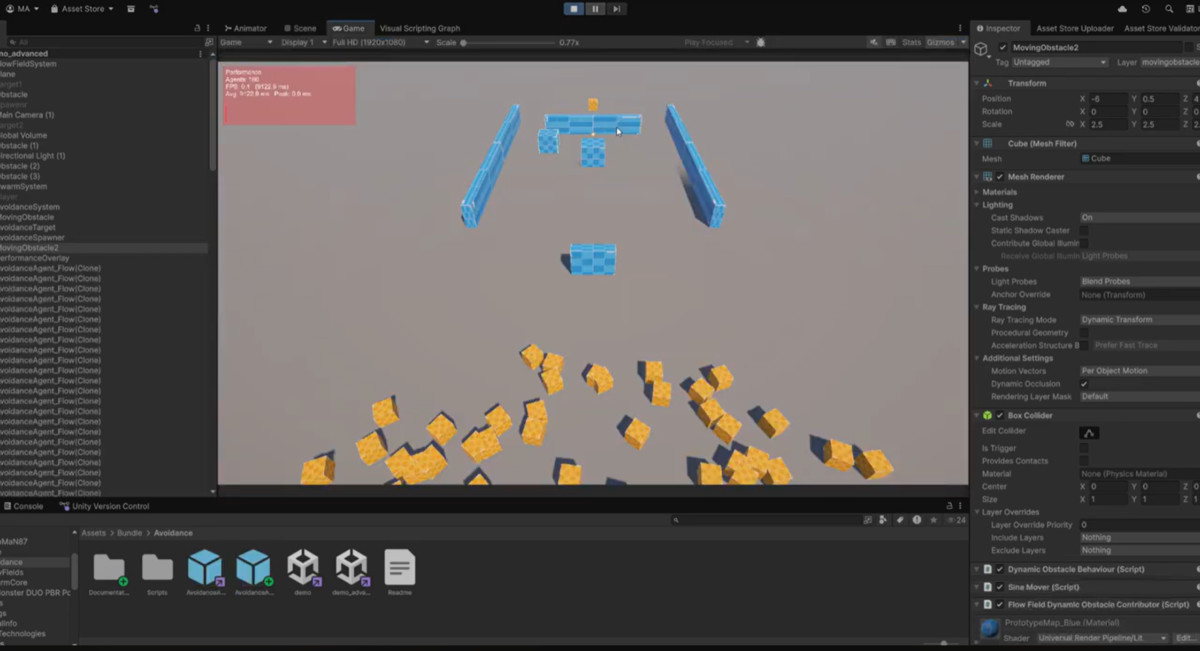
- Dynamic obstacle avoidance for moving blockers
- Obstacle and cost-field avoidance integrations
Steering Behaviours
- Seek, flee, arrive, follow, pursue, wander, orbit, density, formation, boids, separation, cohesion, and alignment behaviours
- Tunable weights and priorities
- Agent priority support for neighbor interactions
- Avoidance urgency reporting so steering can yield under collision pressure
- Vertical movement preservation for flying agents
Designed To Integrate
- Works standalone as a local steering and avoidance layer
- Integrates with Swarm Core agents through adapters
- Integrates with Flow Fields for global-plus-local navigation
- Supports debug visualization for steering, avoidance, obstacle fields, and cost gradients
- Includes Burst/job-compatible ORCA solver groundwork for optimized workflows
If you want mass movement that looks good, scales well, and avoids heavy per-agent pathfinding, this module is built for that.
From the publisher's Asset Store listing.
Technical details
Engine
- Unity compatible
- URP, HDRP, and Built-in Render Pipeline supported
- No render-pipeline-specific runtime dependency
Platforms
- PC, console, and mobile
- Performance depends on agent count, neighbor radius, update rate, and enabled modules
Core Approach
- Local avoidance and steering layer for many-agent movement
- Can run standalone or as part of a larger swarm navigation stack
- Designed to combine global direction input with local collision resolution
Algorithms / Options
- Predictive agent-agent avoidance
- ORCA 2D reciprocal collision avoidance
- ORCA 3D-style avoidance for flying agents
- Continuum-style crowd avoidance
- Dynamic obstacle avoidance
- Cost-field and obstacle-field avoidance
- Weight- and priority-based steering composition
Steering
- Seek, Flee, Arrive, Follow, Pursue, Wander, Orbit
- Separation, Cohesion, Alignment
- Boids-style combined steering
- Formation steering
- Density steering
- Velocity blending and smoothing
- Vertical movement preservation for flying agents
Integration
- Standalone usage supported
- Optional integration with Swarm Core
- Optional integration with Flow Fields
- Adapter-based IAvoidanceAgent support
- Compatible with ground, terrain-following, and flying agents
Debugging
- Debug visualization for steering vectors
- Avoidance intent and velocity direction visualization
- Obstacle field and cost gradient debug support
- Helpful for tuning neighbor radius, weights, and priorities
Performance Notes
- Intended for large groups of agents
- Neighbor sampling radius, max neighbors, and update rate strongly affect performance
- ORCA 2D solver includes bounded solve behavior to reduce worst-case spikes
- Burst/job-compatible ORCA solver groundwork included for optimized workflows
- Use simpler modules or lower update rates for very large mobile scenes.
Compatibility
| Unity version | Built-in | URP | HDRP | Custom |
|---|---|---|---|---|
| 6000.2.8f1 | Compatible | Compatible | Compatible | Compatible |
As listed on the Asset Store.