
 View on Asset Store (opens in new tab)
Package details
- Latest version
- 1.2
- Last updated
- First released
- Unity version
- 6000.6.3 or later
- Package size
- 615 KB
- Files
- 66
- Views in the past week
- 7
Price tracking
- Last checked
- Tracked since
- Lowest recorded
- $9.99 on
Keywords
Lidar Component - Mini Map (Basic)
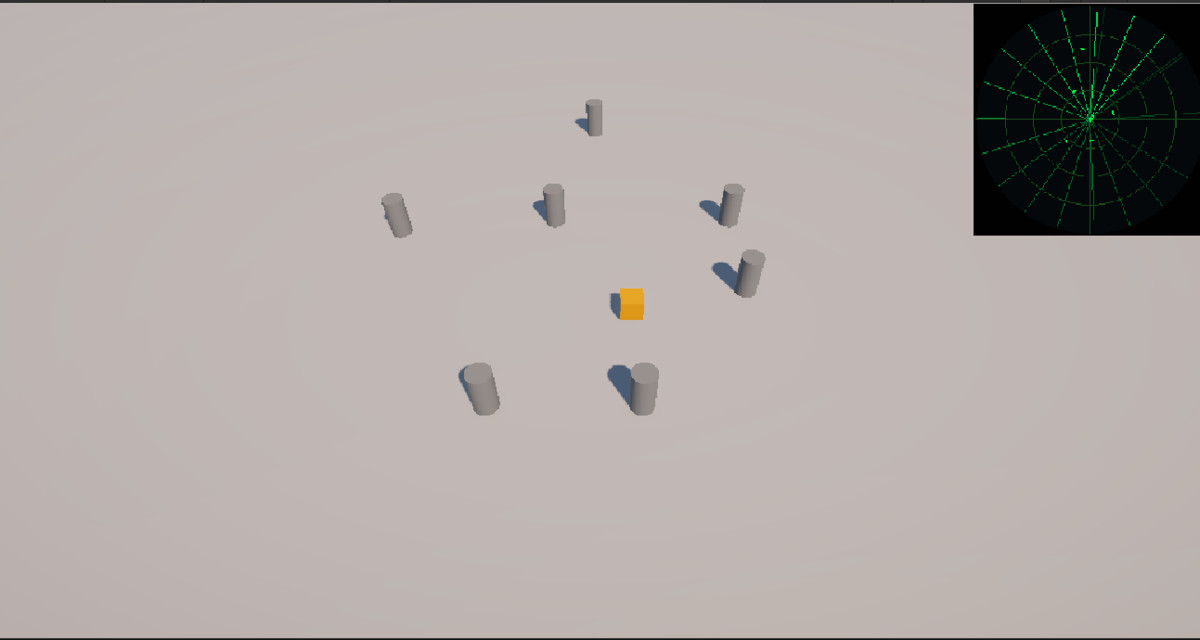
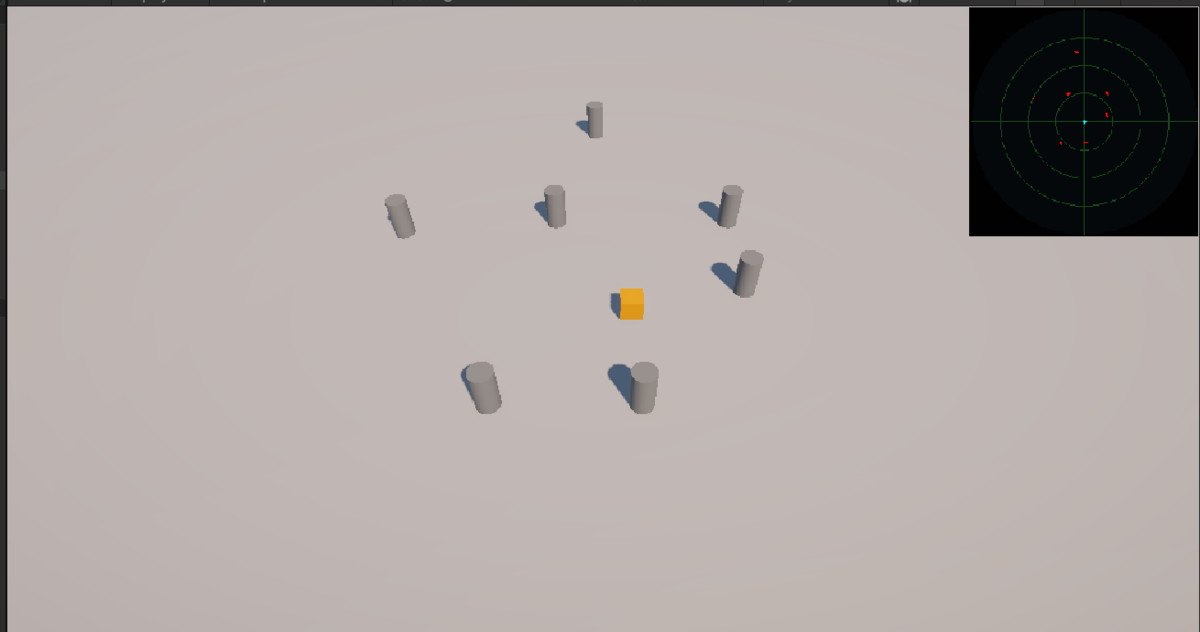
A lightweight LiDAR sensor simulation for Unity featuring a CPU-based raycast backend, scan patterns, and radar visualization. P.S. Underpriced on purpose. I like coffee and fair entry points.
Affiliate link · Purchases support this site
Price history
Last 6 months
USDAsset preview
1 / 6
Lidar Component - Mini Map (Basic) screenshot 1
About this asset
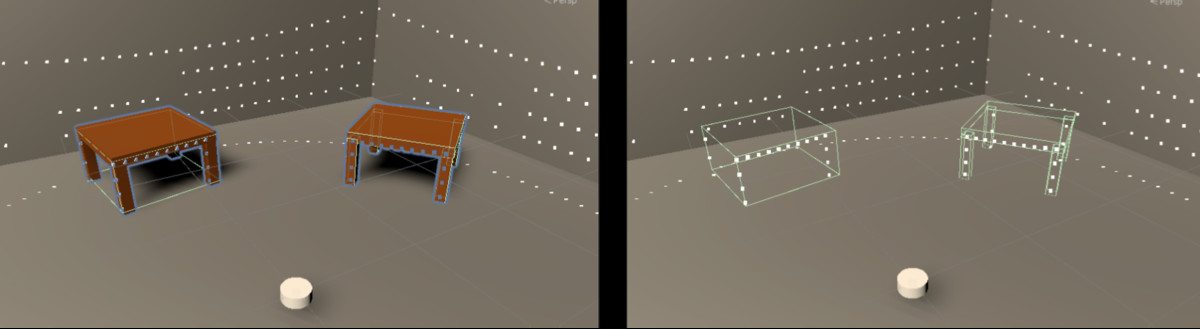
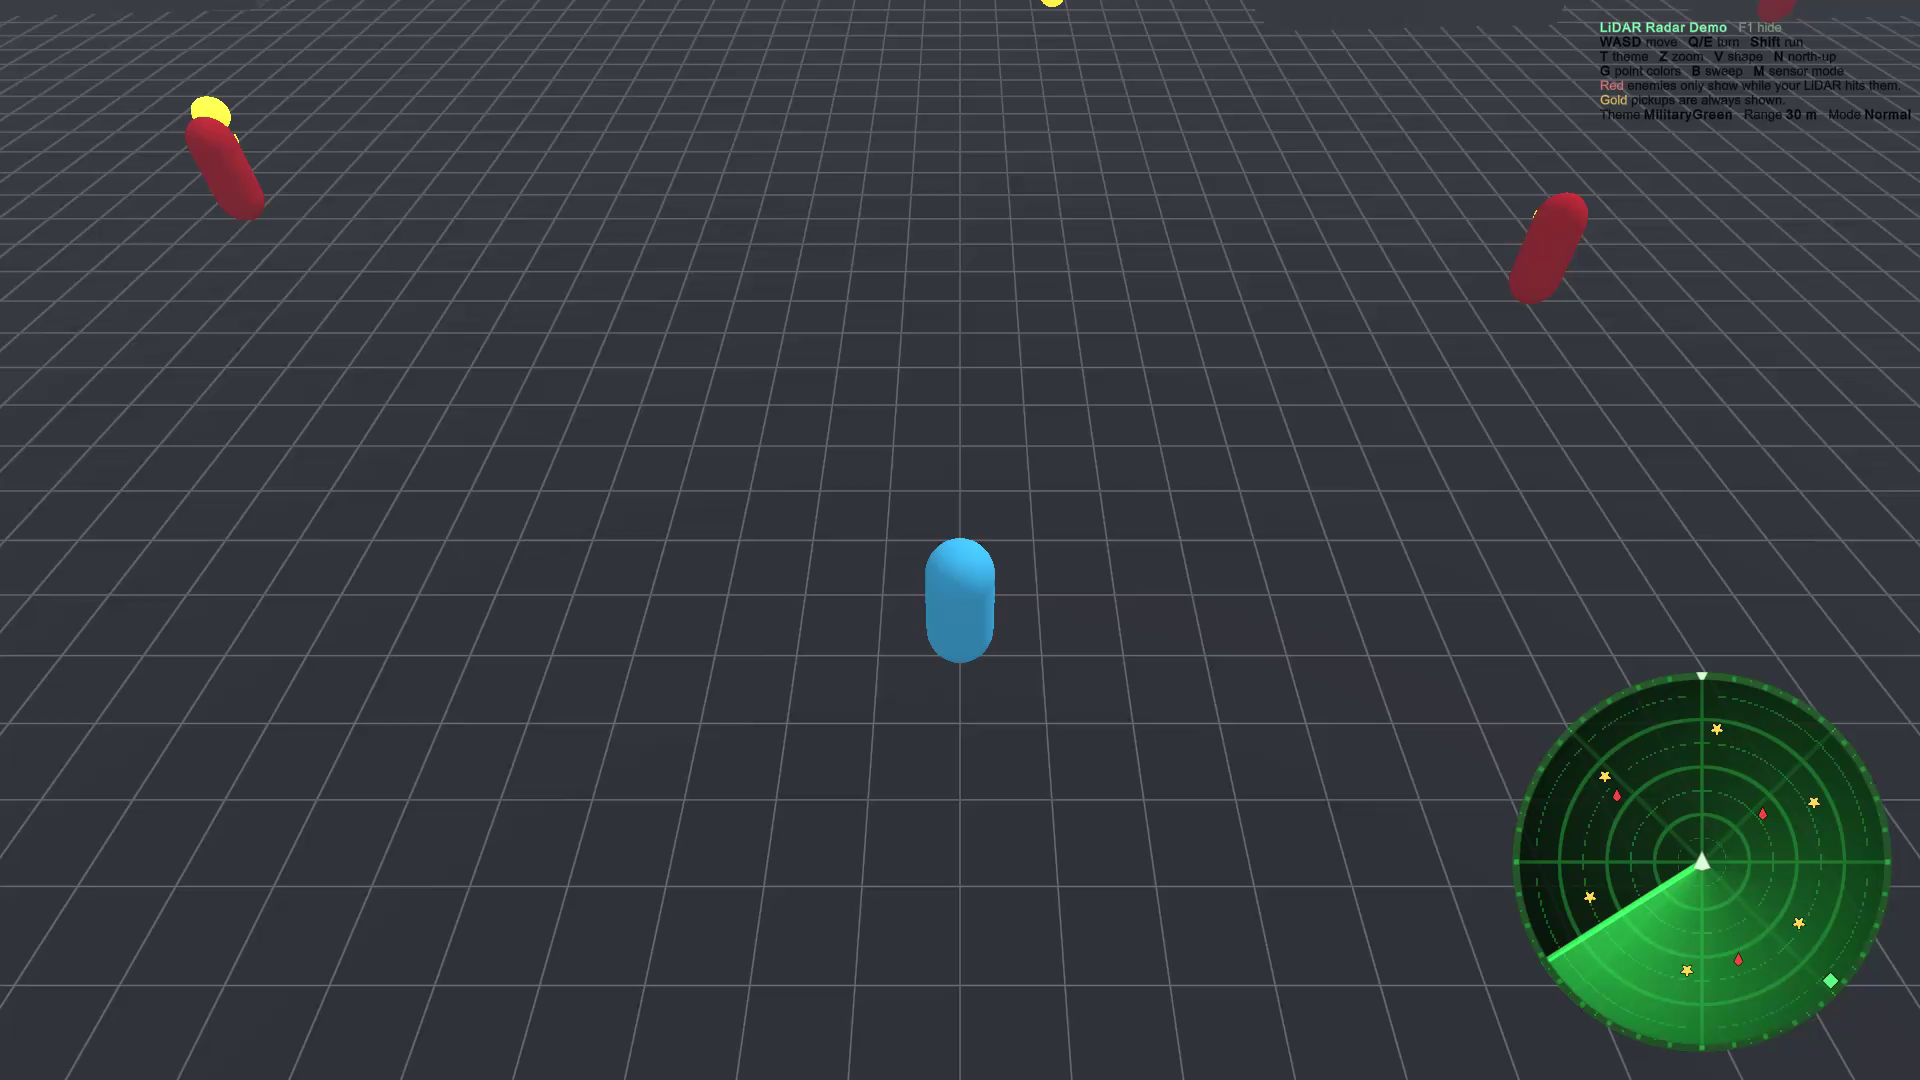
The LiDAR Component– Basic Package provides a real-time LiDAR sensor simulation built specifically for Unity. It enables developers to simulate realistic LiDAR scans using CPU-based raycasting, visualize sensor output through a radar-style minimap, and filter detections at the sensor level using layers and scan rings.
The system is designed with a clean, modular architecture that separates sensing, processing, and visualization. This allows the LiDAR data to be reused across different consumers such as HUDs, analytics tools, or future robotics integrations.
While the Basic package focuses on reliability and ease of use, the architecture is intentionally Pro-ready. Advanced features such as GPU backends, hardware ray tracing, occupancy grids, and ROS publishers are planned as optional Pro extensions without breaking the existing API.
This package is ideal for:
- Game developers needing sensor-based perception
- Simulation and AI prototyping
- Robotics concept demonstrations without ROS complexity
- Educational and research visualization
From the publisher's Asset Store listing.
Technical details
Core Features
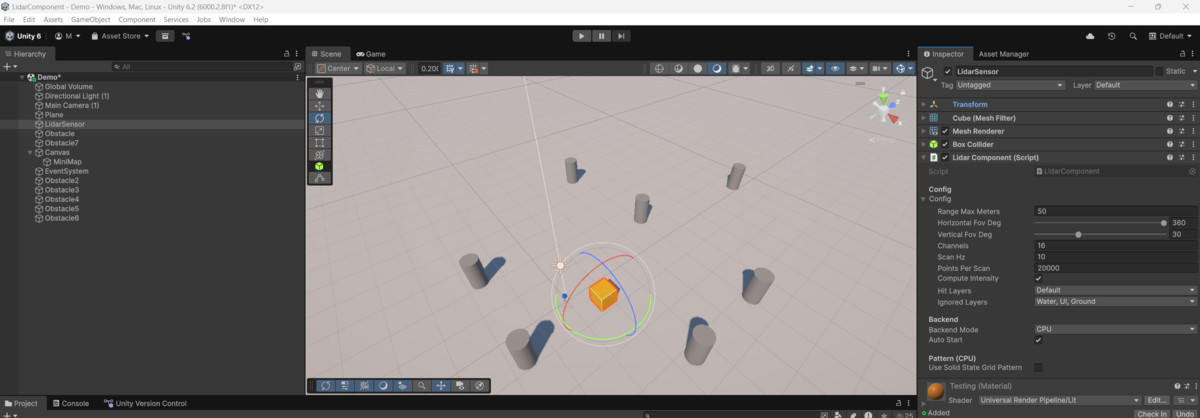
- CPU-based LiDAR backendRaycast-driven point generation
Deterministic and engine-agnostic behavior - Configurable LiDAR parametersRange, horizontal/vertical FOV
Scan frequency (Hz)
Number of channels (rings)
Points per scan - Sensor-level filteringLayer-based hit and ignore masks
Multi-layer exclusion support - Ring filteringIgnore specific rings or ranges
Useful for ground return suppression - Real-time radar / minimap visualizationSensor-centered display
Point fading and persistence
Ring separation and styling
Architecture
- Modular backend system (ILidarBackend)
- Clean data contract (LidarFrame, LidarPoint)
- Decoupled visualization and processing
- Graceful fallback system for unavailable backends
- Designed for future Pro extensions
Backend Support (Basic)
- ✅ CPU Raycast Backend
- ⛔ GPU Backend (Pro)
- ⛔ Hybrid Backend (Pro)
- ⛔ Hardware Ray Tracing Backend (Pro)
Performance Notes
- Suitable for real-time use in small to medium scenes
- Performance scales with:
Number of points per scan
Scan frequency
Scene complexity - Layer filtering strongly recommended for optimal performance
Engine & Compatibility
- Unity (Built-in / URP compatible)
- Requires standard Unity Physics (colliders)
- No external dependencies
- No ROS required in Basic package
Compatibility
| Unity version | Built-in | URP | HDRP | Custom |
|---|---|---|---|---|
| 6000.6.3f1 | Compatible | Compatible | Compatible | Compatible |
As listed on the Asset Store.