
 View on Asset Store (opens in new tab)
Package details
- Latest version
- 2.0
- Last updated
- First released
- Unity version
- 6000.2.8 or later
- Package size
- 447 KB
- Files
- 160
- Favorites
- 14
- Views in the past week
- 20
Price tracking
- Last checked
- Tracked since
- Lowest recorded
- $14.99 on
Keywords
Swarm AI Toolkit – Navigation Bundle
Navigation Bundle 2.0 combines Swarm Core, Flow Fields, and Steering + Avoidance into a scalable movement stack for crowds, RTS units, and flying swarms.
Affiliate link · Purchases support this site
Price history
Last 6 months
USDAsset preview
1 / 10
Swarm AI Toolkit – Navigation Bundle screenshot 1

About this asset
Swarm AI Toolkit - Navigation Bundle
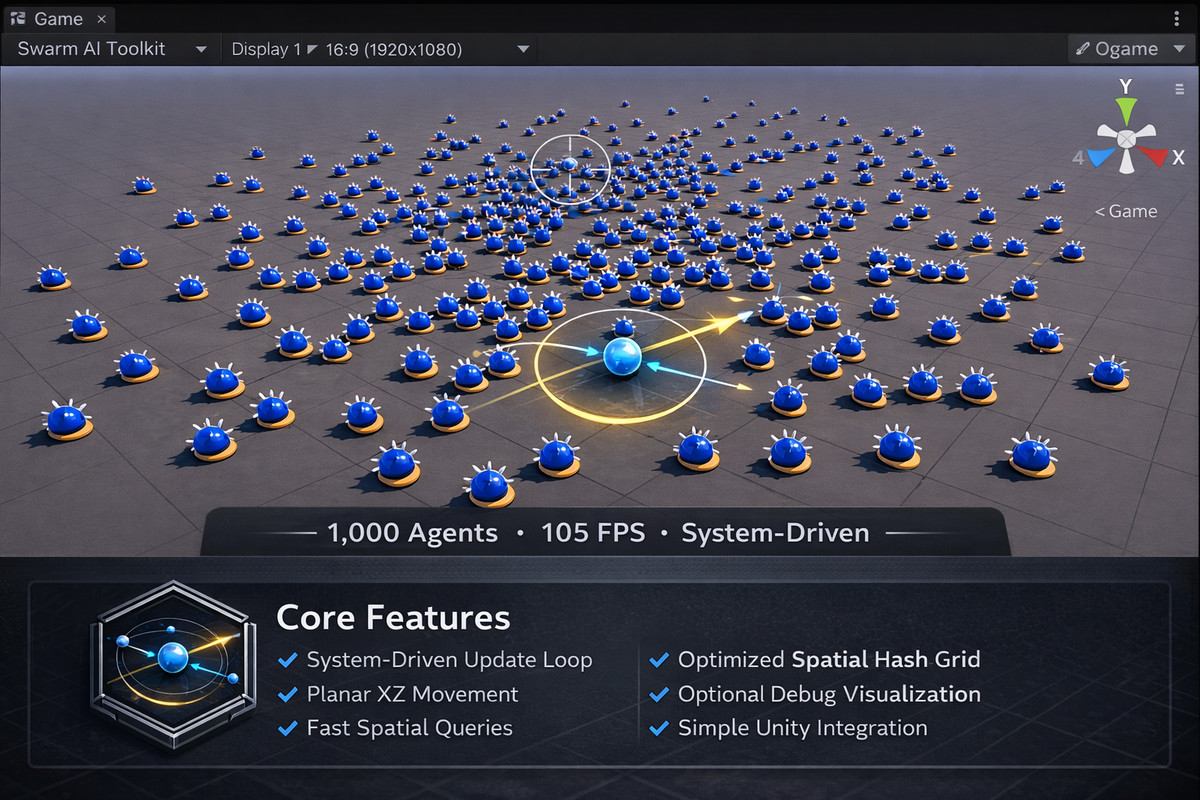
The Navigation Bundle combines the main movement systems of the Swarm AI Toolkit:
- Swarm AI Toolkit - Core
- Swarm AI Toolkit - Flow Fields
- Swarm AI Toolkit - Steering + Avoidance
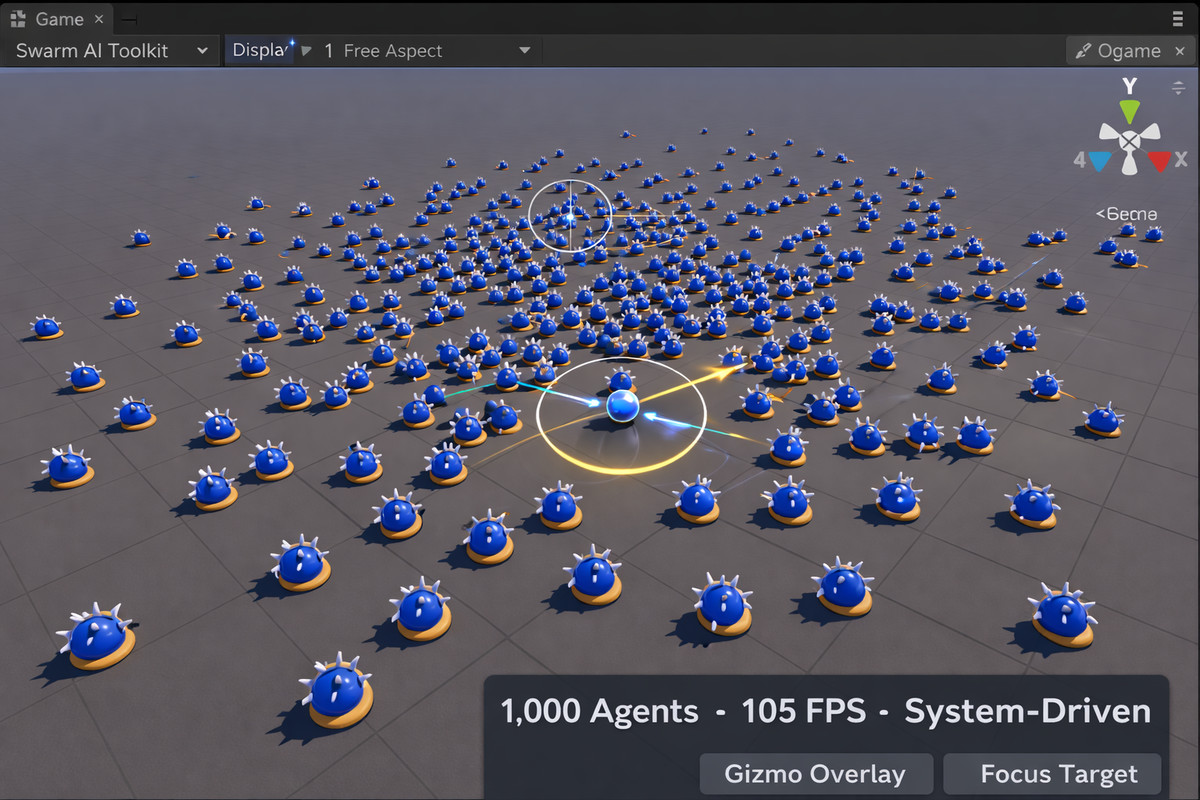
Together, they provide a scalable, system-driven solution for simulating, navigating, and locally steering large groups of agents in Unity.
This bundle is designed for projects that need stable large-scale unit movement without relying on Rigidbody physics, heavy per-agent pathfinding, or NavMesh-driven crowds. It supports flat XZ movement, terrain-following agents, and flying-style 3D swarm setups.
What This Bundle Provides
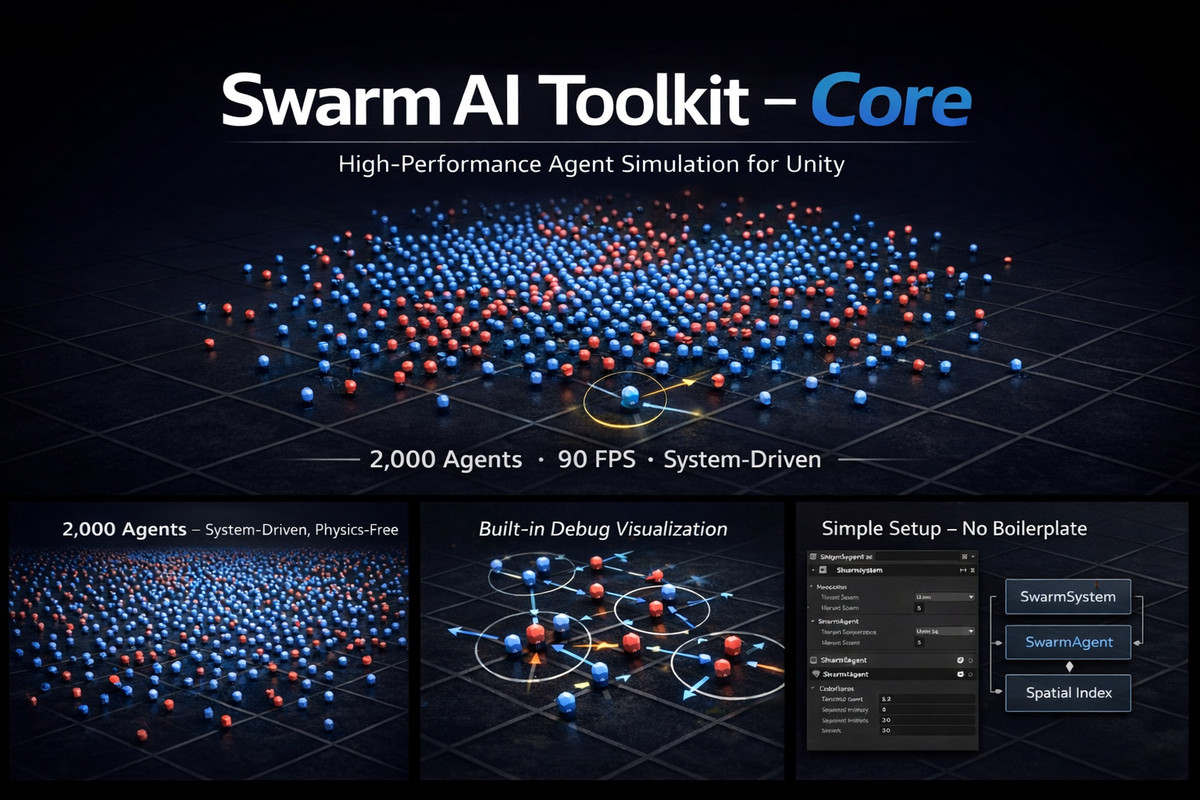
Swarm AI Toolkit - Core
A high-performance agent simulation foundation featuring:
- Centralized system-driven updates
- Lightweight agent movement
- 2D and 3D spatial hash queries
- Physics-free movement
- Job-system movement groundwork
- Separation support
- Optional debug visualization
Core is responsible for efficient agent simulation and neighbor lookup at scale.
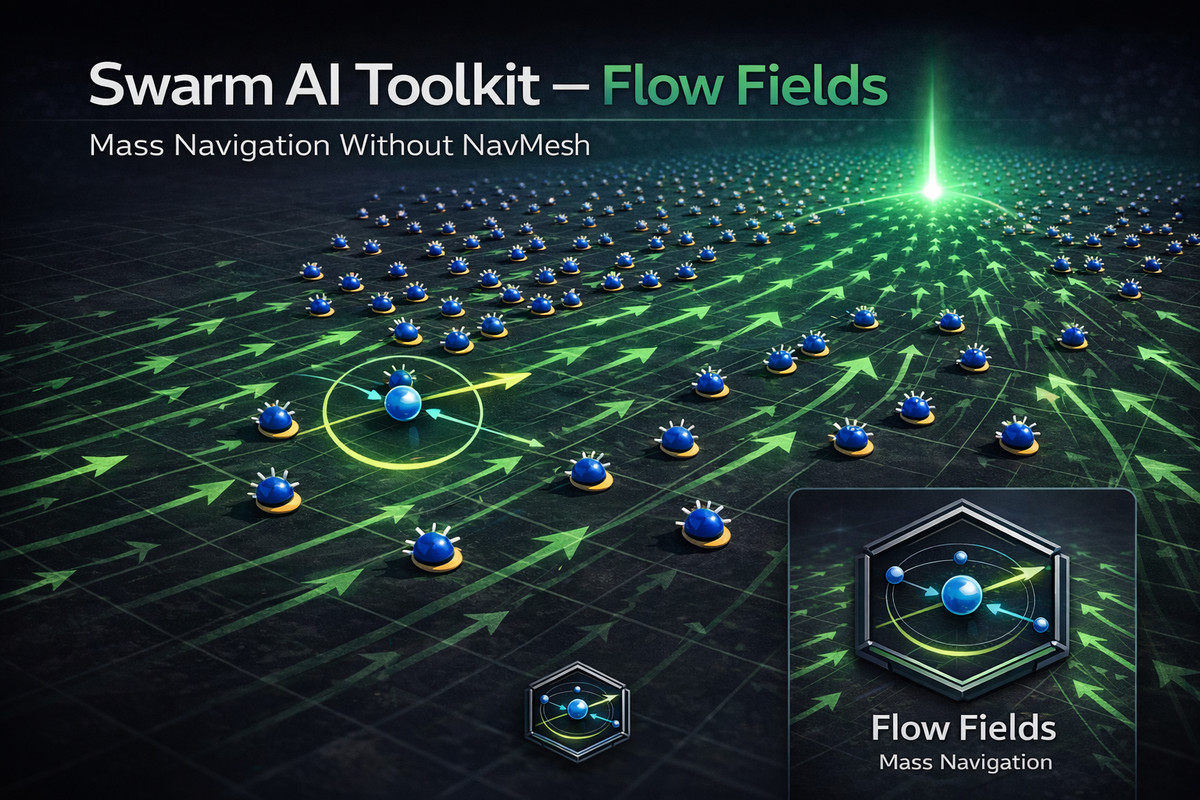
Swarm AI Toolkit - Flow Fields
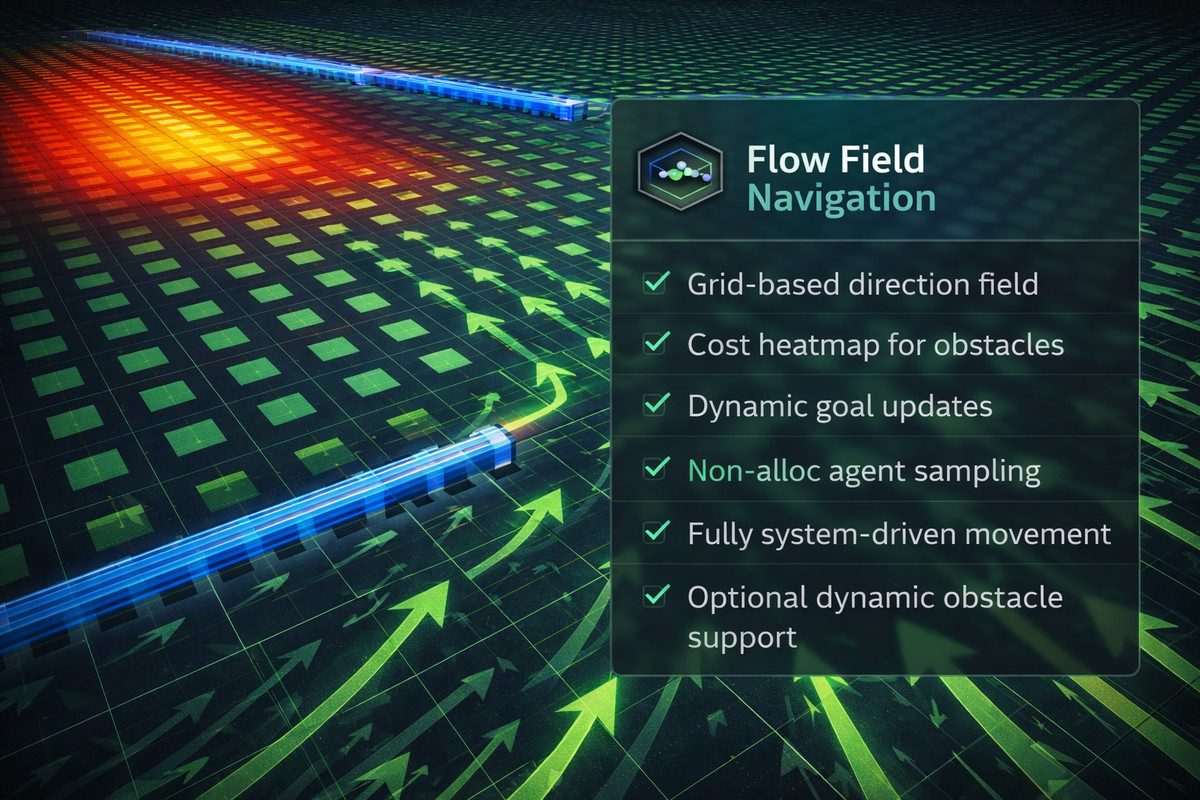
A grid-based global navigation system that:
- Generates shared direction fields
- Avoids per-agent pathfinding
- Supports single-layer and layered navigation
- Supports dynamic targets and dynamic costs
- Supports terrain, raycast, fixed-altitude, and heightmap-based height workflows
- Integrates with Swarm Core movement
Flow Fields provides global navigation direction for large groups of agents simultaneously.
Swarm AI Toolkit - Steering + Avoidance
A local movement layer that provides:
- Predictive local avoidance
- ORCA 2D reciprocal avoidance
- ORCA 3D-style avoidance for flying agents
- Continuum crowd avoidance
- Dynamic obstacle avoidance
- Steering behaviours such as seek, flee, arrive, follow, pursue, wander, formation, boids, separation, cohesion, and alignment
- Agent priorities, weights, smoothing, and debug visualization
Steering + Avoidance handles local collision resolution and natural movement on top of global flow direction.
Designed For
- RTS unit movement
- Tower defense waves
- MOBA-style minions
- Large crowd systems
- Swarm simulations
- Strategy games with mass unit control
- Terrain-following ground agents
- Flying swarms and layered navigation setups
Why This Bundle
By combining Core, Flow Fields, and Steering + Avoidance, this bundle provides:
- Efficient large-scale simulation
- Shared global navigation direction
- Local avoidance and natural steering
- Stable performance at scale
- Clean modular architecture
- No required NavMesh dependency
- No required Rigidbody overhead
- Support for ground, terrain-following, and flying agents
It forms the movement foundation of the Swarm AI Toolkit ecosystem and can be used on its own or extended with additional AI modules such as Perception and Decision.
From the publisher's Asset Store listing.
Technical details
Engine & Compatibility
- Unity 2021 LTS or newer recommended
- Compatible with Built-in Render Pipeline, URP, and HDRP
- No render-pipeline-specific runtime dependencies
- No required third-party runtime libraries
- PC, console, and mobile supported, depending on agent count and settings
Architecture Overview
The Navigation Bundle consists of three modular movement systems:
1. Swarm Core - Agent Simulation Layer
- Centralized system-driven update loop
- Lightweight agent movement
- 2D planar and 3D spatial query support
- Spatial hash grid for neighbor and proximity queries
- Physics-free movement model
- Radius-based agent representation
- Managed fallback path
- Burst/job-system groundwork for movement, spatial hash rebuilds, and separation
- Designed for large agent counts
2. Flow Fields - Global Navigation Layer
- Grid-based cost field generation
- Shared direction fields for groups of agents
- Single-layer and layered flow-field navigation
- Multi-target direction field support
- Dynamic target updates
- Static and dynamic cost stamping
- Dynamic cost contributors
- Terrain, raycast, fixed-altitude, and baked-heightmap height workflows
- No per-agent pathfinding
- Designed for mass movement scenarios
3. Steering + Avoidance - Local Movement Layer
- Predictive agent-agent collision avoidance
- ORCA 2D reciprocal avoidance option
- ORCA 3D-style avoidance for flying agents
- Continuum-style crowd avoidance option
- Dynamic obstacle avoidance
- Cost-field and obstacle-field avoidance
- Steering behaviours including seek, flee, arrive, follow, pursue, wander, orbit, density, formation, boids, separation, cohesion, and alignment
- Velocity blending, smoothing, weights, and priorities
- Avoidance urgency reporting for stable behavior under collision pressure
Movement Pipeline
- Global direction from Flow Fields
- Local avoidance adjustment
- Steering blend and behavior weighting
- Swarm Core movement integration
- Optional terrain or fixed-altitude projection
- Final agent position and velocity
Performance Characteristics
- Designed for large-scale simulations with hundreds to thousands of agents
- Performance depends on:Agent count
Flow-field grid resolution
Neighbor query radius
Max neighbor count
Avoidance module settings
Update rate and rebuild intervals - Non-alloc query paths used where possible
- Spatial hashing reduces broad-phase query cost
- Dynamic flow-field rebuilds can be skipped when contributors have not changed
- No Rigidbody components required for default movement
- No Unity NavMesh dependency required
- System-driven update model with lightweight agent components
Movement Model
- Supports planar XZ movement
- Supports terrain-following ground agents
- Supports fixed-altitude and flying-style agents
- Supports 3D neighbor queries for flying swarms
- Configurable radius, speed, mass, steering weights, and priority
- Height projection can be handled through terrain, raycast, fixed altitude, or heightmap sampling
Integration
- Swarm Core can run standalone
- Flow Fields integrates directly with Swarm Core
- Steering + Avoidance can run standalone or through Swarm Core adapters
- Flow Field cost data can be used by avoidance modules
- Designed for modular extension
- Compatible with custom AI decision systems
- Can be combined with separate Perception and Decision modules
Limitations
- Flow Fields are grid-based and primarily XZ-oriented for global navigation
- Flying support is suitable for layered/fixed-altitude and steering-driven vertical movement, not full volumetric 3D pathfinding
- No built-in animation controller
- No built-in combat logic
- No required NavMesh crowd simulation
- Very large scenes require tuning grid size, update rates, neighbor radius, and avoidance settings.
Compatibility
| Unity version | Built-in | URP | HDRP | Custom |
|---|---|---|---|---|
| 6000.2.8f1 | Compatible | Compatible | Compatible | Compatible |
As listed on the Asset Store.